
Examples
 [Example: Rosenbrock Function] |
 [Example: Ball and Plate] |
 [Example: Tanks] |
 [Example: Nonlinear Estimation] |
 [Example: AGV navigation] |
 [Example: Inverted Pendulum] |
OpEn+F1TENTH: this complete example on how to use OpEn to build an NMPC controller for autonomous racing cars competitions using the F1TENTH simulator ground vehicle.
 [An example of a F1/10 car model]
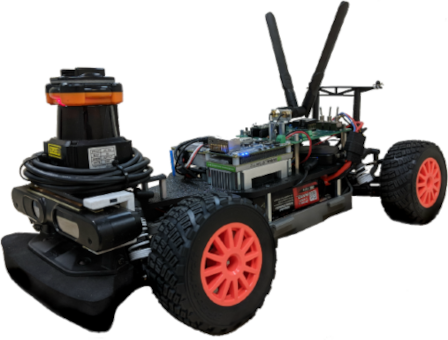
OpEn generates a complete ROS package that can run along with the simulator. To build your own ROS package read the documentation first.
OpEn+ROS: this complete example on how to use OpEn to build an NMPC controller on a Husky ground vehicle.
 [Clearpath Husky unmanned ground vehicle]
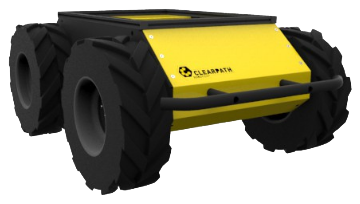
OpEn generates a complete ROS package that can run on the robot. To build your own ROS package read the documentation first.
Previous
ROS packages
Next
Getting started